
Yichu (Bill) Yang — Robotics Researcher at NVIDIA
I am a robotics researcher at NVIDIA, working on physical AI, world models, and robot learning. Previously, I worked at Seed Robotics, ByteDance, and Xiaomi Robotics Lab.
I received my MS in Robotics from Northeastern University, with a concentration in Mechanical Engineering, and my BS in Mechanical Engineering from Shanghai Jiao Tong University.
My research spans robot learning, control, mechanical design, and rapid prototyping, with an emphasis on building robust systems that transfer from research to real-world deployment.
🔥 News
- 2026.05: 🎉 Cosmos 3 released—an open omnimodal world foundation model for physical AI reasoning, generation, and action.
- 2025.07: 🎉 GR-3 released—a large-scale VLA model designed for generalization, long-horizon tasks, and dexterous manipulation.
- 2024.09: 🎉 GR-2 released—a generative VLA model achieving a 97.7% average success rate across more than 100 tasks.
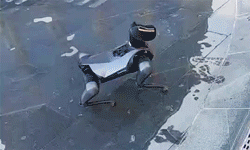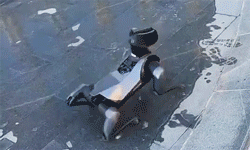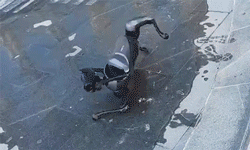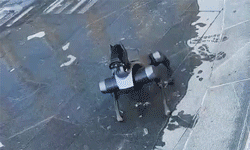
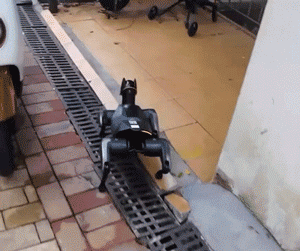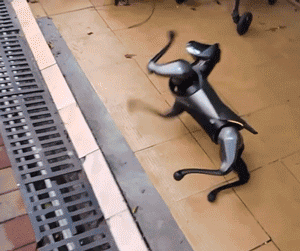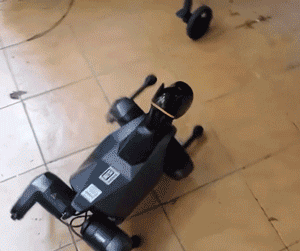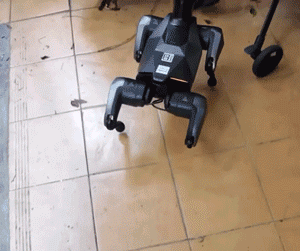
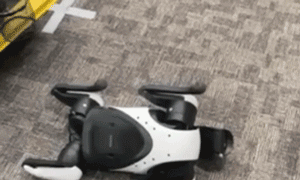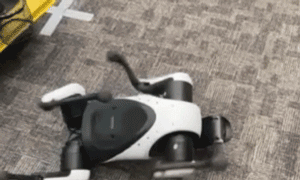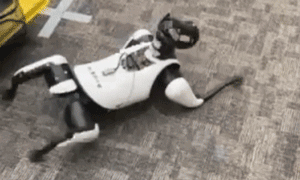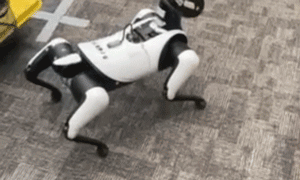
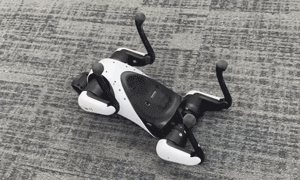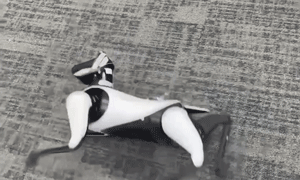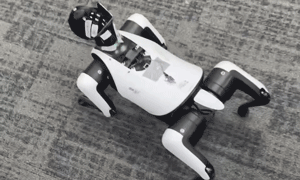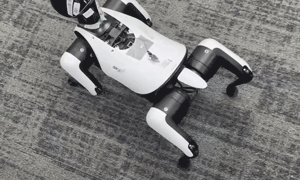
- 2023.06: 🎉 CyberDog 2 released with AI-powered autonomous fall recovery.
📝 Publications
Cosmos 3: Omnimodal World Models for Physical AI
NVIDIA et al., Yichu Yang
- The first fully open omnimodel that unifies physical reasoning, world generation, and action generation
- A Mixture-of-Transformers architecture supporting language, image, video, audio, and action in one model
- Released as Cosmos 3 Super (64B), Nano (16B), and Edge (4B), covering large-scale generation through real-time deployment
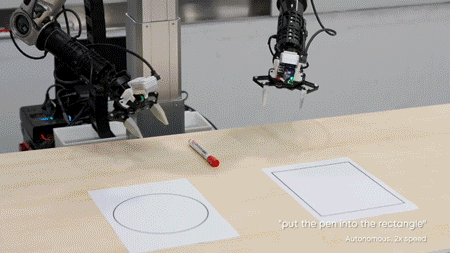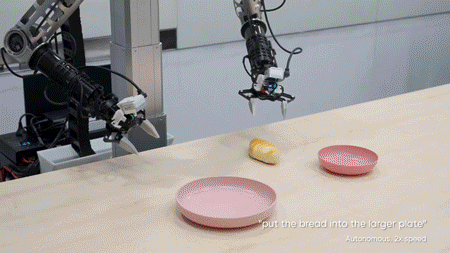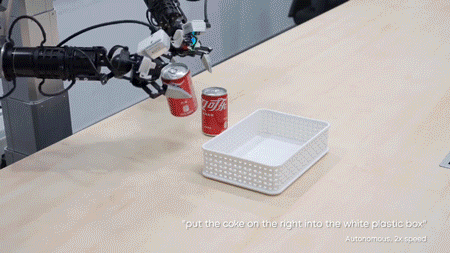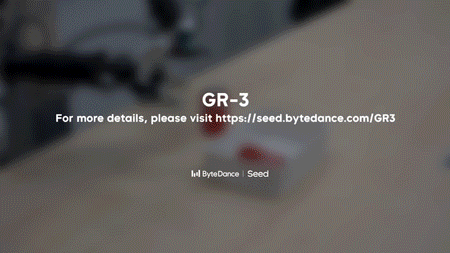
GR-3 Technical Report
Chilam Cheang, Sijin Chen, Zhongren Cui, Yingdong Hu, Liqun Huang, Tao Kong, Hang Li, Yifeng Li, Yuxiao Liu, Xiao Ma, Hao Niu, Wenxuan Ou, Wanli Peng, Zeyu Ren, Haixin Shi, Jiawen Tian, Hongtao Wu, Xin Xiao, Yuyang Xiao, Jiafeng Xu, Yichu Yang
- GR-3 showcases exceptional capabilities in generalizing to novel objects, environments, and instructions involving abstract concepts.
- GR-3 also excels in handling long-horizon and dexterous tasks
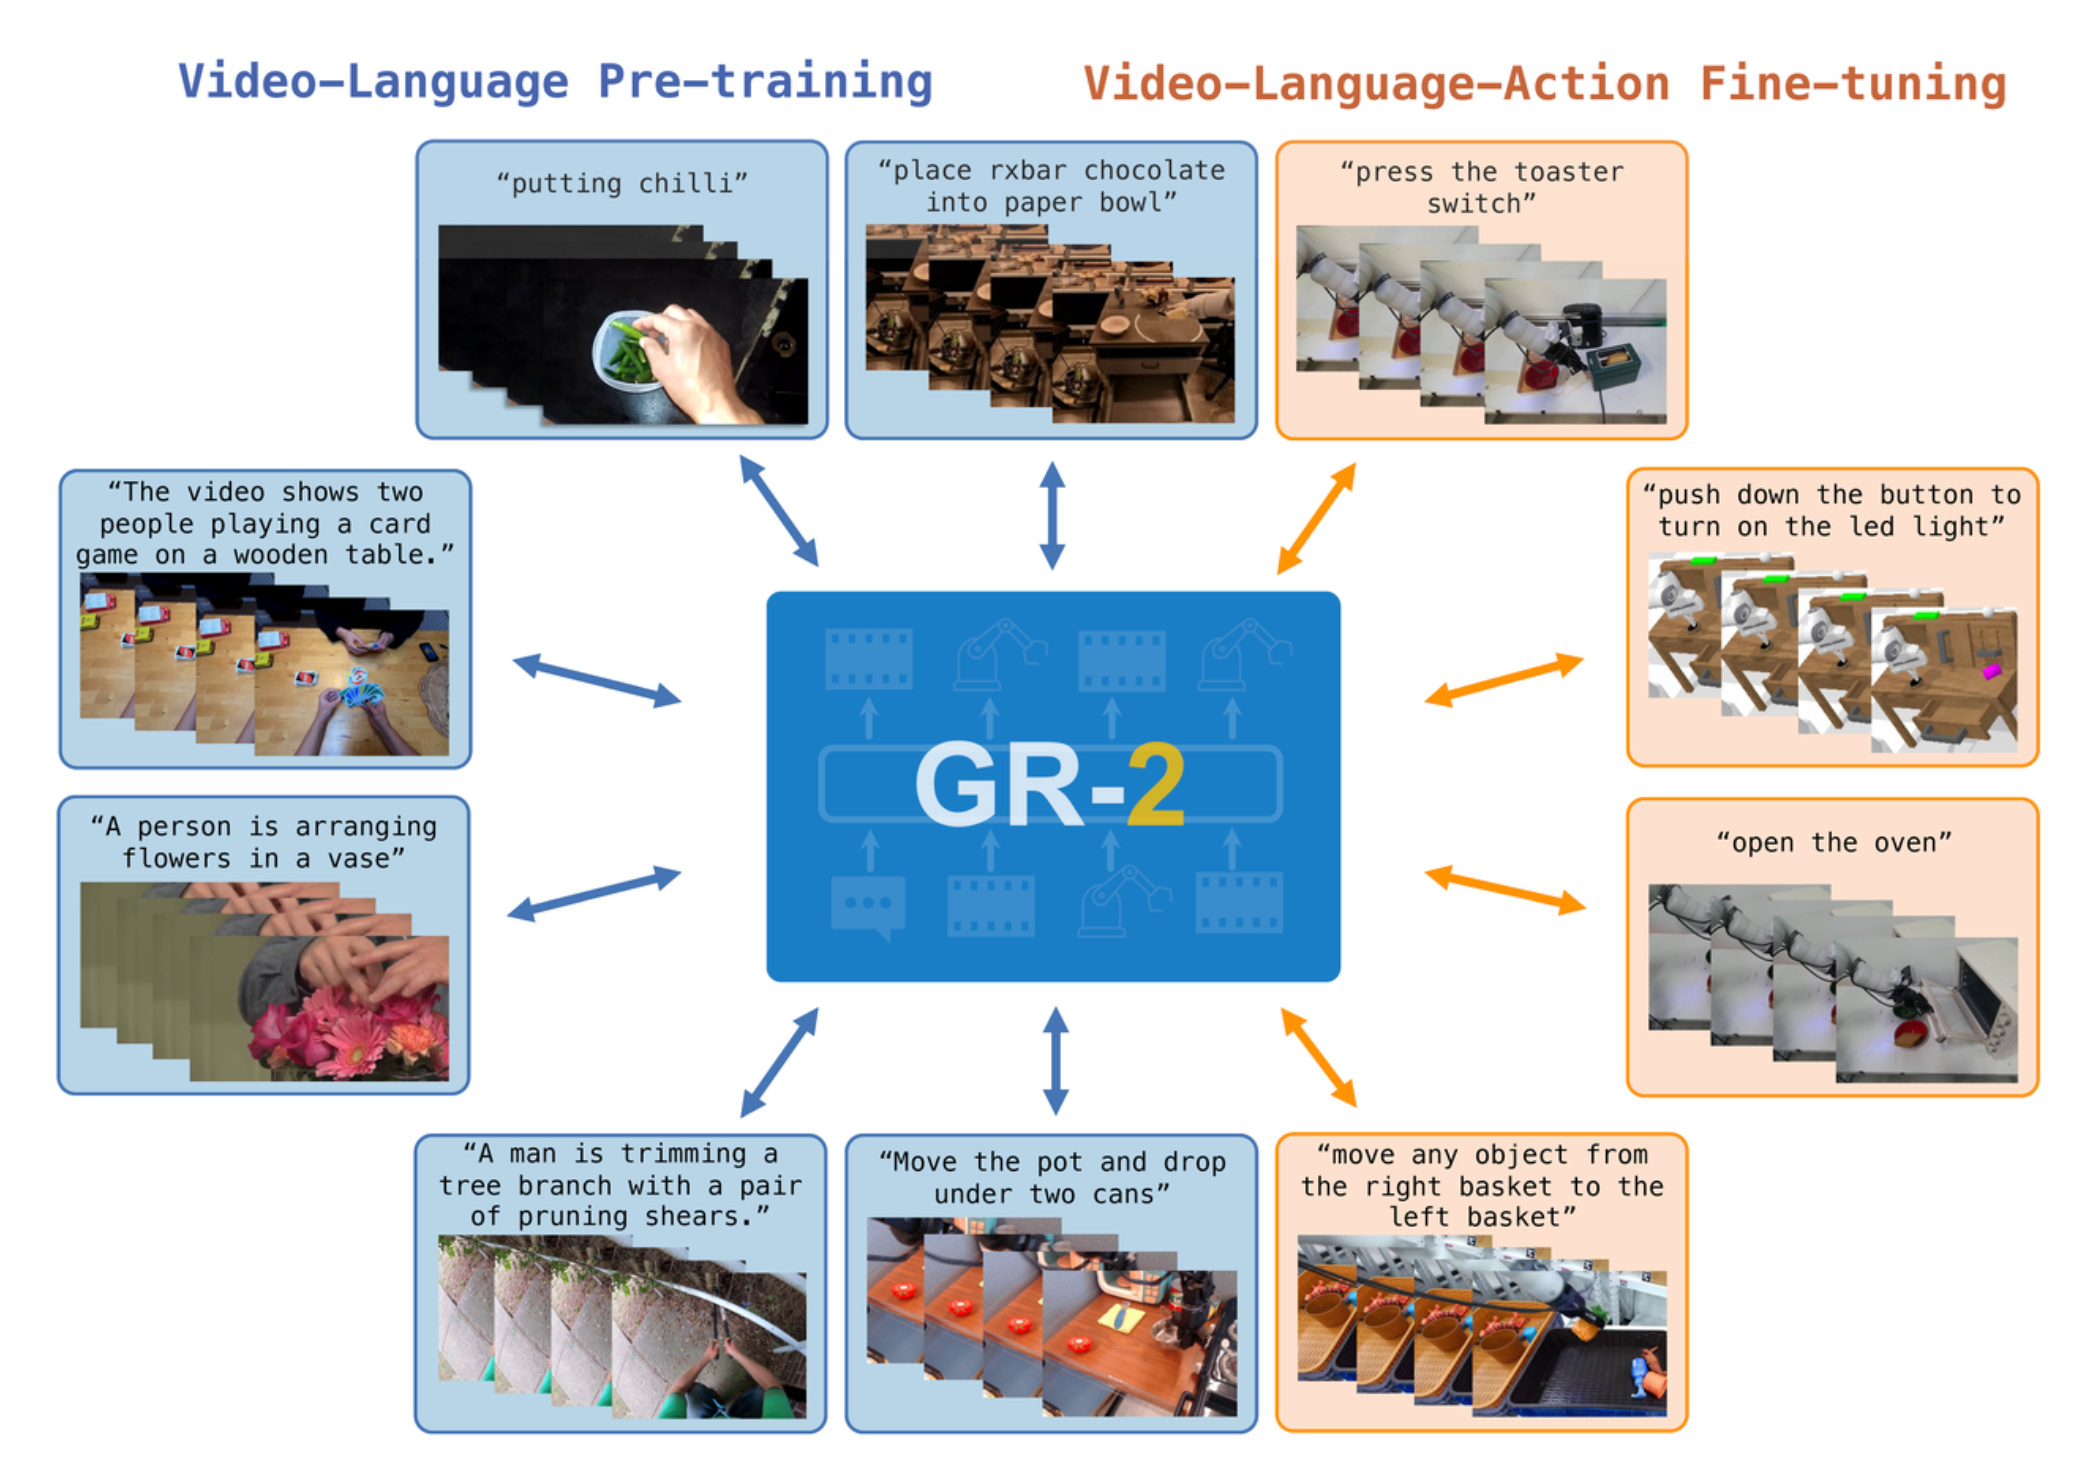
GR-2: A Generative Video-Language-Action Model with Web-Scale Knowledge for Robot Manipulation
Chi-Lam Cheang, Guangzeng Chen, Ya Jing, Tao Kong, Hang Li, Yifeng Li, Yuxiao Liu, Hongtao Wu, Jiafeng Xu, Yichu Yang, Hanbo Zhang, Minzhao Zhu
- GR-2 achieves a 97.7% success rate across 100+ tasks
- GR-2 excels in industrial scenarios like end-to-end picking and adapts well to unseen environments.
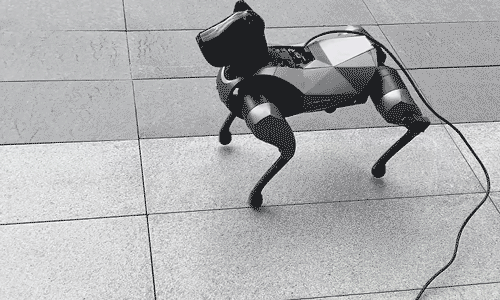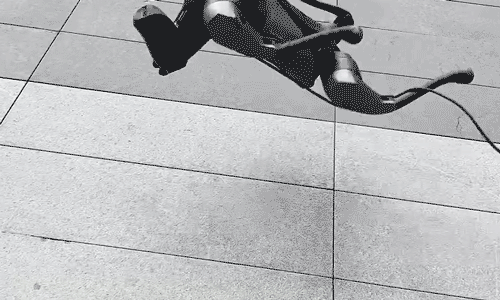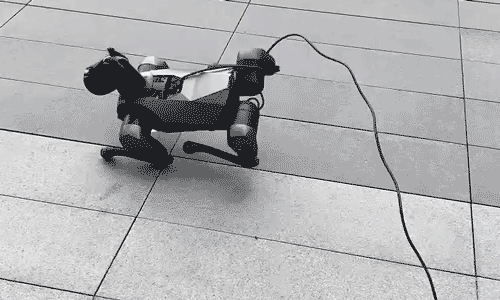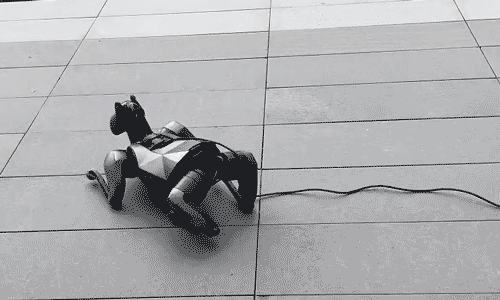
 State Estimation Transformers for Agile Legged Locomotion
Chen Yu, Yichu Yang, Tianlin Liu, Yangwei You, Mingliang Zhou, Diyun Xiang
- Accepted by IROS 2024
- Best Paper Runner-Up at Deployable@CoRL2023
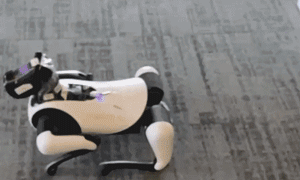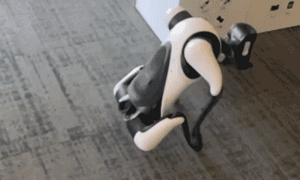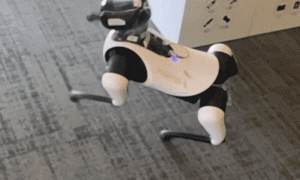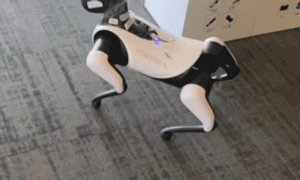
- The policy was successfully deployed on Cyberdog2, enabling it to execute agile maneuvers such as running jumps, running backflips, and running sideflips
🔍 Research and Projects
Product-Level Robust Fall Recovery Across Diverse Terrains
Learning Agile Locomotion and Acrobatic Motions
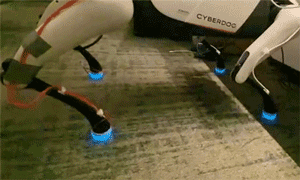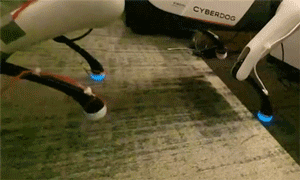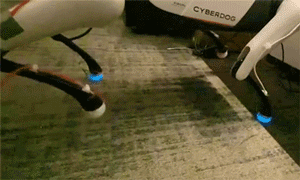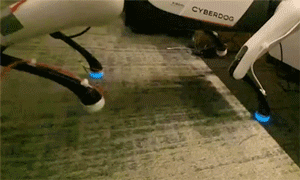
Hall-Effect Foot Contact Sensor for Quadruped Robots
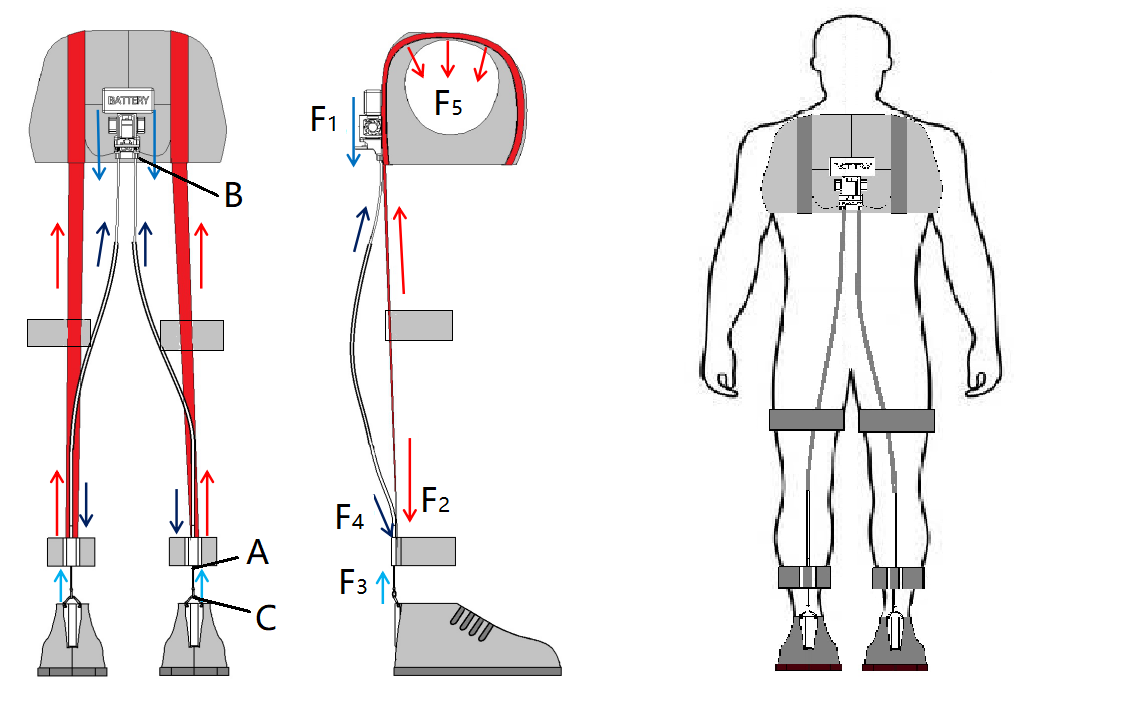
 Biomechanical Simulation-Guided Soft Exoskeleton Design
💼 Work Experience
- Present, Robotics Researcher, NVIDIA.
- Previously, Researcher, Seed Robotics, ByteDance.
- 2022.07 - 2024.01, Researcher, Xiaomi Robotics Lab, Xiaomi.
- 2021.06 - 2022.03, RA, Khoury College of Computer Sciences, Northeastern University.
- 2019.05 - 2019.12, Mechatronics Engineer, Qlibrium (previously CamMed)
📖 Education
- 2018.09 - 2021.06, Robotics, Khoury College of Computer Sciences, Northeastern University.
- 2014.09 - 2018.06, Mechanical Engineering, Shanghai Jiao Tong University.